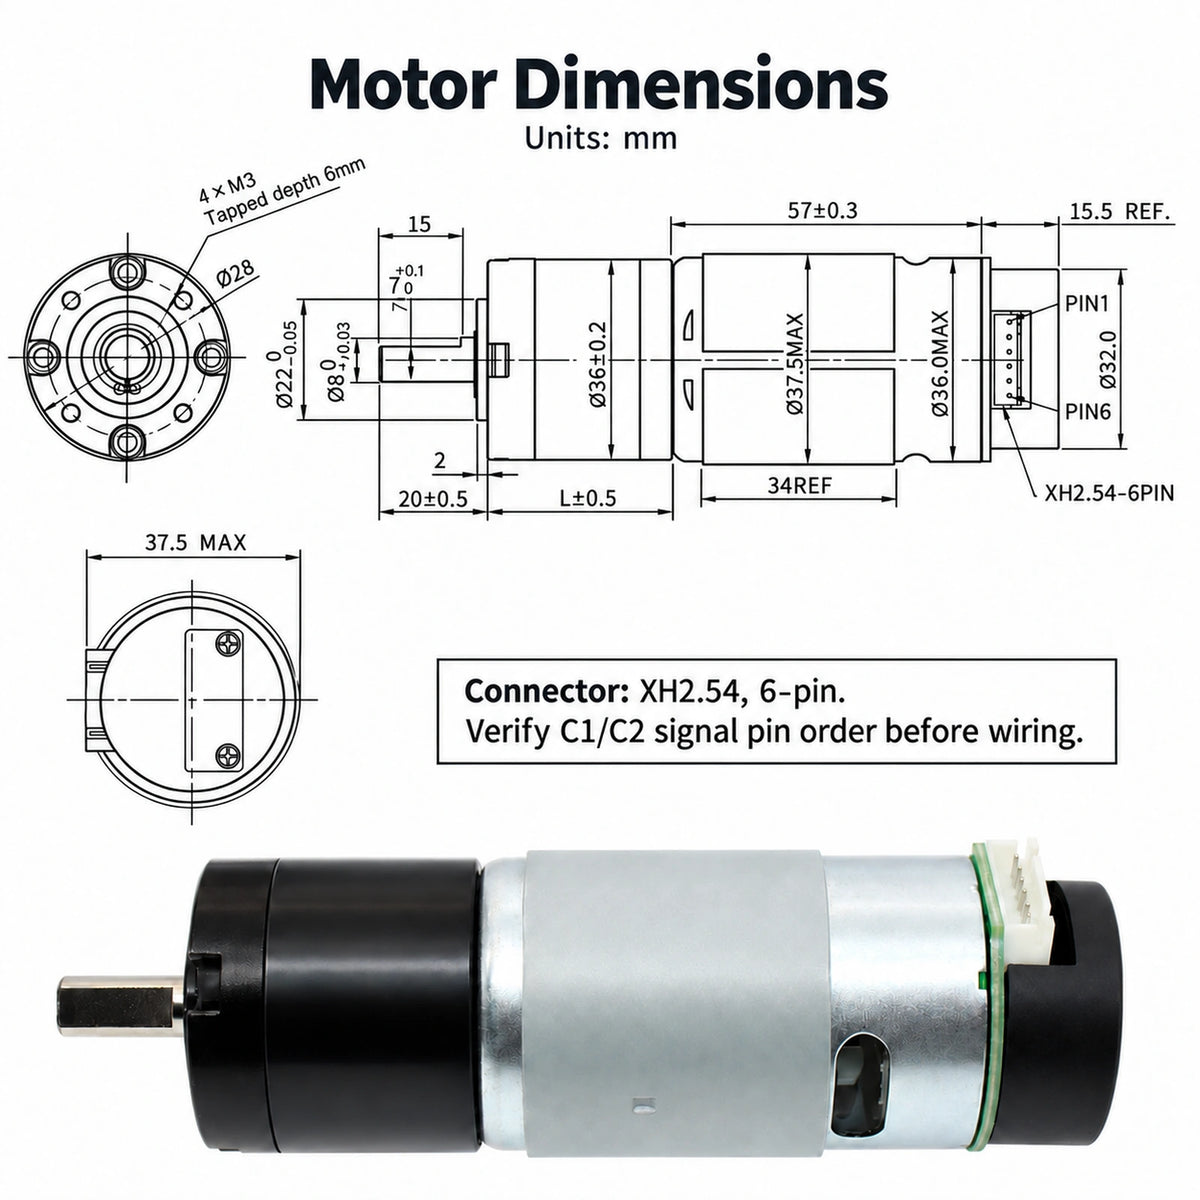
Description
The CHIHAI CHP-36GP-555 is a high-torque 36mm planetary DC gear motor equipped with an incremental Hall encoder for speed and position feedback.
Built around a 555 brushed DC motor and planetary reduction gearbox, it provides a wide selection of gear ratios from 3.7:1 to 515:1 for applications requiring different combinations of speed and torque.
The integrated AB-phase Hall encoder provides square-wave quadrature outputs and supports 3.3V or 5V encoder supply voltage. Encoder resolution increases according to the selected gearbox ratio, making the motor suitable for closed-loop motion control, speed measurement and positioning applications.
The motor features an 8mm D-shaped output shaft supported by dual ball bearings and is available in 12V and 24V configurations.
It is suitable for mobile robots, AGVs, smart vehicles, automation equipment, camera mechanisms and other high-torque electromechanical systems.
Key Features
- 36mm planetary DC gear motor
- 555 brushed DC motor
- Integrated AB-phase Hall encoder
- 12V and 24V versions
- Wide 3.7:1–515:1 gear ratio range
- 8mm D-shaped output shaft
- Dual ball-bearing output support
- Up to 120W maximum power at 24V
- Encoder supply supports 3.3V or 5V DC
- XH2.54 6-pin connector
- 17 PPR base Hall encoder
- Quadrature A/B square-wave output
- Multiple speed and torque configurations
- Suitable for closed-loop robotic drive systems
General Specifications
| Specification | Value |
|---|---|
| Brand | CHIHAI |
| Model | CHP-36GP-555 |
| Motor Type | Brushed DC Planetary Gear Motor |
| Motor Size | 555 |
| Gearbox Diameter | 36 mm |
| Voltage Options | 12V / 24V DC |
| Output Shaft Diameter | 8 mm |
| Shaft Type | D-Shaped |
| Shaft Flat Dimension | 7 mm |
| Output Shaft Length | 20 mm |
| Output Support | Dual Ball Bearings |
| Approx. Weight | 480 g |
| Connector | XH2.54-6PIN |
| Encoder | AB-Phase Incremental Magnetic Hall Encoder |
| Encoder Supply | 3.3V / 5V DC |
| Base Encoder Resolution | 17 PPR |
| Hall Magnetic Poles | 34 poles / 17 pole pairs |
| Encoder Output | Square-Wave A/B Phase |
| Encoder Response Frequency | 100 kHz |
| Gear Ratios | 3.7:1–515:1 |
| Max Power @ 12V | 30 W |
| Max Power @ 24V | 120 W |
Hall Encoder Pinout
| Pin | Function | Wire |
|---|---|---|
| PIN1 | M2 Motor Power − | White |
| PIN2 | Encoder VCC 3.3V / 5V | Blue |
| PIN3 | C2 Hall Encoder B Output | Green |
| PIN4 | C1 Hall Encoder A Output | Yellow |
| PIN5 | Encoder GND | Black |
| PIN6 | M1 Motor Power + | Red |
Important: The Hall encoder supply is 3.3V or 5V DC and should not be connected directly to the motor's 12V or 24V power supply.
12V Performance Specifications
| Gear Ratio | No-Load Speed | Rated Speed | Rated Torque | Rated Current | Stall Torque |
|---|---|---|---|---|---|
| 3.7:1 | 1600 RPM | 1200 RPM | 0.15 N·m | ≤2.0 A | ≥4.0 kg·cm |
| 5.2:1 | 1150 RPM | 850 RPM | 0.25 N·m | ≤2.0 A | ≥7.0 kg·cm |
| 14:1 | 420 RPM | 320 RPM | 0.50 N·m | ≤2.0 A | ≥15.0 kg·cm |
| 19:1 | 310 RPM | 250 RPM | 0.75 N·m | ≤2.0 A | ≥22.0 kg·cm |
| 27:1 | 220 RPM | 170 RPM | 1.25 N·m | ≤2.0 A | ≥25.0 kg·cm |
| 51:1 | 115 RPM | 95 RPM | 1.70 N·m | ≤2.0 A | ≥35.0 kg·cm |
| 100:1 | 60 RPM | 45 RPM | 3.0 N·m | ≤2.0 A | ≥50.0 kg·cm |
| 139:1 | 42 RPM | 32 RPM | 4.0 N·m | ≤2.0 A | ≥50.0 kg·cm |
| 264:1 | 22 RPM | 18 RPM | 5.0 N·m | ≤2.0 A | ≥60.0 kg·cm |
| 515:1 | 11.5 RPM | 10 RPM | 6.0 N·m | ≤2.0 A | ≥60.0 kg·cm |
12V no-load current: ≤400mA
12V stall current: ≤10A
24V Performance Specifications
| Gear Ratio | No-Load Speed | Rated Speed | Rated Torque | Rated Current | Stall Torque |
|---|---|---|---|---|---|
| 3.7:1 | 3200 RPM | 2400 RPM | 0.30 N·m | ≤2.7 A | ≥8.0 kg·cm |
| 5.2:1 | 2300 RPM | 1750 RPM | 0.50 N·m | ≤2.7 A | ≥10.0 kg·cm |
| 14:1 | 650 RPM | 650 RPM | 1.0 N·m | ≤2.7 A | ≥25.0 kg·cm |
| 19:1 | 630 RPM | 500 RPM | 1.5 N·m | ≤2.7 A | ≥30.0 kg·cm |
| 27:1 | 440 RPM | 350 RPM | 2.5 N·m | ≤2.7 A | ≥35.0 kg·cm |
| 51:1 | 230 RPM | 190 RPM | 3.5 N·m | ≤2.7 A | ≥50.0 kg·cm |
| 100:1 | 120 RPM | 90 RPM | 5.0 N·m | ≤2.7 A | ≥50.0 kg·cm |
| 139:1 | 85 RPM | 65 RPM | 5.0 N·m | ≤2.7 A | ≥50.0 kg·cm |
| 264:1 | 45 RPM | 35 RPM | 5.0 N·m | ≤2.7 A | ≥60.0 kg·cm |
| 515:1 | 23 RPM | 18 RPM | 6.0 N·m | ≤2.7 A | ≥60.0 kg·cm |
24V no-load current: ≤600mA
24V stall current: ≤21A
Gearbox & Encoder Data
| Gear Ratio | Encoder Counts After Gearbox | Gearbox Length |
|---|---|---|
| 3.7:1 | 62.9 | 26.5 mm |
| 5.2:1 | 88.4 | 26.5 mm |
| 14:1 | 238 | 34.5 mm |
| 19:1 | 323 | 34.5 mm |
| 27:1 | 459 | 34.5 mm |
| 51:1 | 867 | 42.5 mm |
| 100:1 | 1700 | 42.5 mm |
| 139:1 | 2363 | 42.5 mm |
| 264:1 | 4488 | 50.5 mm |
| 515:1 | 8755 | 50.5 mm |
Applications
- Mobile robots
- AGV drive systems
- Smart tracking vehicles
- Self-balancing robots
- Robotic platforms
- Automation equipment
- Smart appliances
- Camera pan/tilt mechanisms
- Motorized mechanisms
- DIY robotics projects
Package Includes
1 × CHP-36GP-555 Planetary Gear Motor with Hall Encoder
The voltage and gear ratio depend on the selected variant.
FAQ
Does this motor include an encoder?
Yes. The CHP-36GP-555 shown here includes an AB-phase incremental magnetic Hall encoder.
What voltage does the Hall encoder use?
The encoder supports a 3.3V or 5V DC supply.
Can the motor run directly from 12V or 24V?
Select the motor voltage that matches your power system. The Hall encoder has a separate 3.3V/5V supply requirement.
What is the encoder resolution?
The Hall encoder has a base resolution of 17 PPR. The effective count after the gearbox depends on the selected gear ratio.
What is the output shaft size?
The motor uses an 8mm D-shaped output shaft with a 20mm output length.
Which gear ratio should I choose?
Lower ratios are intended for higher output speed, while higher ratios provide lower output speed and greater torque.