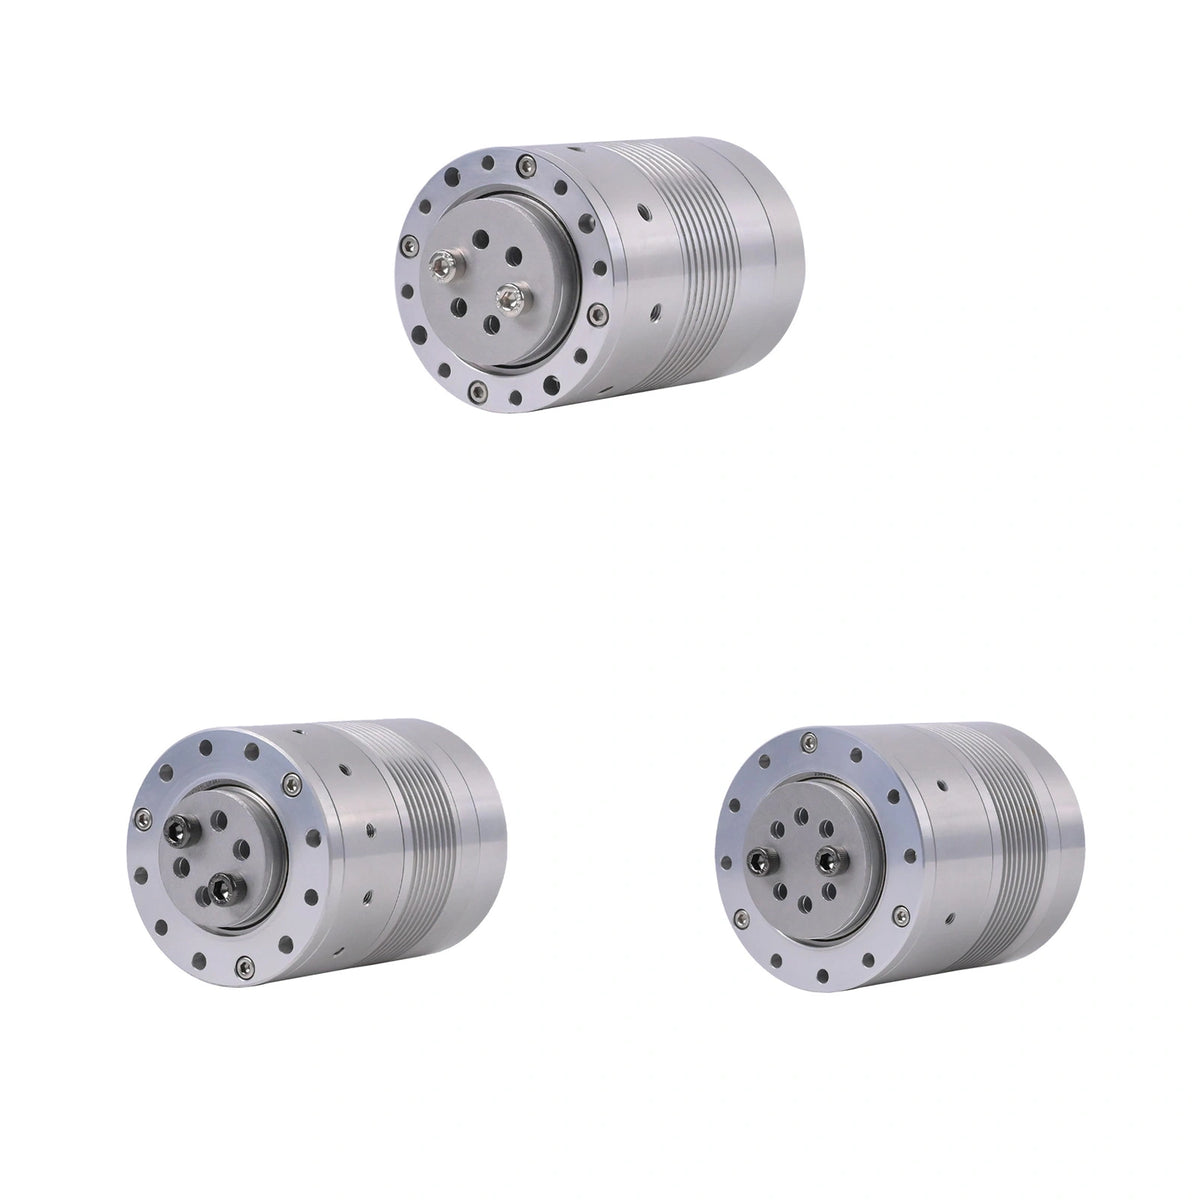
Description
The EC-A Series Integrated Robot Joint Servo Actuator combines a high-torque servo motor, precision reduction mechanism, dual encoder feedback, cross-roller bearing, and CAN communication in a compact integrated package.
Designed for collaborative robots, humanoid robots, robotic arms, quadruped robots, exoskeletons, and precision automation systems, the EC-A Series provides high torque density with compact dimensions and low backlash.
Three models are available to cover different joint load requirements:
-
EC-A3814-H14-107 — 20 N·m rated torque, 60 N·m peak torque
-
EC-A5013-H17-100 — 30 N·m rated torque, 90 N·m peak torque
-
EC-A6013-H20-100 — 40 N·m rated torque, 130 N·m peak torque
All three models operate at 48V, support CAN communication at 1 Mbps, feature dual encoders, and use an integrated cross-roller bearing structure for compact robotic joint integration.
Key Features
-
Integrated robot joint servo actuator
-
High-ratio precision reduction mechanism
-
Up to 130 N·m peak torque
-
48V rated operating voltage
-
CAN communication
-
1 Mbps communication baud rate
-
Dual encoder feedback
-
10 arcsec specified backlash
-
Integrated cross-roller bearing
-
High torque density
-
Compact integrated mechanical structure
-
Designed for precision robotic joints
-
Three torque and size options available
Model Comparison
| Specification | EC-A3814-H14-107 | EC-A5013-H17-100 | EC-A6013-H20-100 |
|---|---|---|---|
| Rated Voltage | 48V | 48V | 48V |
| Reduction Ratio | 107:1 | 100:1 | 100:1 |
| Rated Power | 134.4W | 120W | 206.4W |
| Rated Torque | 20 N·m | 30 N·m | 40 N·m |
| Peak Torque | 60 N·m | 90 N·m | 130 N·m |
| Rated Speed | 47 RPM | 33 RPM | 45 RPM |
| Peak Speed | 52 RPM | 38 RPM | 47 RPM |
| Rated Bus Current | 2.8A | 2.5A | 4.3A |
| Rated Phase Current | 4.0A | 3.0A | 5.2A |
| Peak Phase Current | 10A | 20A | 25A |
| Torque Constant | 4.2 N·m/A | 5.9 N·m/A | 5.6 N·m/A |
| Average Efficiency | 51% | 31% | 45% |
| Backlash | 10 arcsec | 10 arcsec | 10 arcsec |
| Communication | CAN | CAN | CAN |
| Baud Rate | 1 Mbps | 1 Mbps | 1 Mbps |
| Dual Encoder | Yes | Yes | Yes |
| Weight | 400g | 640g | 880g |
| Motor Size | Ø53 × 78.5mm | Ø63 × 81.5mm | Ø73 × 84mm |
| Axial / Radial Load* | 1.89 kN | 1.89 kN | 2.14 kN |
| Bending Moment Resistance | 28 N·m | 28 N·m | 40 N·m |
| Cross-Roller Bearing | 3005 | 3005 | 4005 |
| Torque Density | 150 N·m/kg | 140.625 N·m/kg | 147.73 N·m/kg |
*The supplied specification lists axial and radial load capability as a combined specification.
EC-A3814-H14-107 Specifications
| Specification | Value |
|---|---|
| Model | EC-A3814-H14-107 |
| Reduction Ratio | 107:1 |
| Rated Voltage | 48V |
| Rated Bus Current | 2.8A |
| Rated Phase Current | 4.0A |
| Rated Power | 134.4W |
| Rated Speed | 47 RPM |
| Rated Torque | 20 N·m |
| Peak Speed | 52 RPM |
| Peak Phase Current | 10A |
| Peak Torque | 60 N·m |
| Average Efficiency | 51% |
| Torque Constant | 4.2 N·m/A |
| Weight | 400g |
| Backlash | 10 arcsec |
| Size | Ø53 × 78.5mm |
| Communication | CAN |
| Communication Baud Rate | 1 Mbps |
| Encoder | Dual Encoder |
| Axial / Radial Load | 1.89 kN |
| Bending Moment Resistance | 28 N·m |
| Cross-Roller Bearing | 3005 |
| Torque Density | 150 N·m/kg |
EC-A5013-H17-100 Specifications
| Specification | Value |
|---|---|
| Model | EC-A5013-H17-100 |
| Reduction Ratio | 100:1 |
| Rated Voltage | 48V |
| Rated Bus Current | 2.5A |
| Rated Phase Current | 3A |
| Rated Power | 120W |
| Rated Speed | 33 RPM |
| Rated Torque | 30 N·m |
| Peak Speed | 38 RPM |
| Peak Phase Current | 20A |
| Peak Torque | 90 N·m |
| Average Efficiency | 31% |
| Torque Constant | 5.9 N·m/A |
| Weight | 640g |
| Backlash | 10 arcsec |
| Size | Ø63 × 81.5mm |
| Communication | CAN |
| Communication Baud Rate | 1 Mbps |
| Encoder | Dual Encoder |
| Axial / Radial Load | 1.89 kN |
| Bending Moment Resistance | 28 N·m |
| Cross-Roller Bearing | 3005 |
| Torque Density | 140.625 N·m/kg |
EC-A6013-H20-100 Specifications
| Specification | Value |
|---|---|
| Model | EC-A6013-H20-100 |
| Reduction Ratio | 100:1 |
| Rated Voltage | 48V |
| Rated Bus Current | 4.3A |
| Rated Phase Current | 5.2A |
| Rated Power | 206.4W |
| Rated Speed | 45 RPM |
| Rated Torque | 40 N·m |
| Peak Speed | 47 RPM |
| Peak Phase Current | 25A |
| Peak Torque | 130 N·m |
| Average Efficiency | 45% |
| Torque Constant | 5.6 N·m/A |
| Weight | 880g |
| Backlash | 10 arcsec |
| Size | Ø73 × 84mm |
| Communication | CAN |
| Communication Baud Rate | 1 Mbps |
| Encoder | Dual Encoder |
| Axial / Radial Load | 2.14 kN |
| Bending Moment Resistance | 40 N·m |
| Cross-Roller Bearing | 4005 |
| Torque Density | 147.73 N·m/kg |
Applications
-
Collaborative robot joints
-
Humanoid robot joints
-
Robotic arms
-
Quadruped robots
-
Exoskeleton systems
-
Industrial robot joints
-
Precision rotary axes
-
Research robots
-
Automated positioning equipment
-
Compact high-torque motion systems
Package Includes
-
1 × EC-A Series Integrated Robot Joint Servo Actuator
Exact model depends on the selected variant.
FAQ
What is the difference between the three models?
The main differences are physical size, reduction ratio, power, speed, and torque capacity. The EC-A3814 is the smallest 20 N·m model, the EC-A5013 provides 30 N·m rated torque, and the EC-A6013 provides 40 N·m rated torque with up to 130 N·m peak torque.
Do these actuators include encoders?
Yes. The supplied specifications list all three models as having dual encoders.
What communication interface is supported?
All three models use CAN communication with a specified baud rate of 1 Mbps.
What voltage do these actuators use?
All three models are rated for 48V.
Are the 60 N·m, 90 N·m and 130 N·m values continuous torque?
No. These are peak torque values. Rated continuous torque is 20 N·m, 30 N·m and 40 N·m respectively.
Which model should I choose?
Choose according to required joint torque, speed, size and payload. EC-A3814 is suited to more compact joints, while EC-A6013 provides the highest torque capacity in this series.
Does the actuator include an integrated bearing?
Yes. The specifications identify an integrated cross-roller bearing: type 3005 for EC-A3814 and EC-A5013, and type 4005 for EC-A6013.