Description
The GIM4310-36 is a compact high-torque robot joint actuator designed for quadruped robots, robotic arms, humanoid robots, exoskeletons and other precision motion-control applications.
It integrates a brushless motor with a 36:1 planetary gearbox in a compact Ø55 mm housing. The actuator delivers 7.38 N·m nominal torque and up to 20.16 N·m stall torque while weighing approximately 300–310 g depending on configuration.
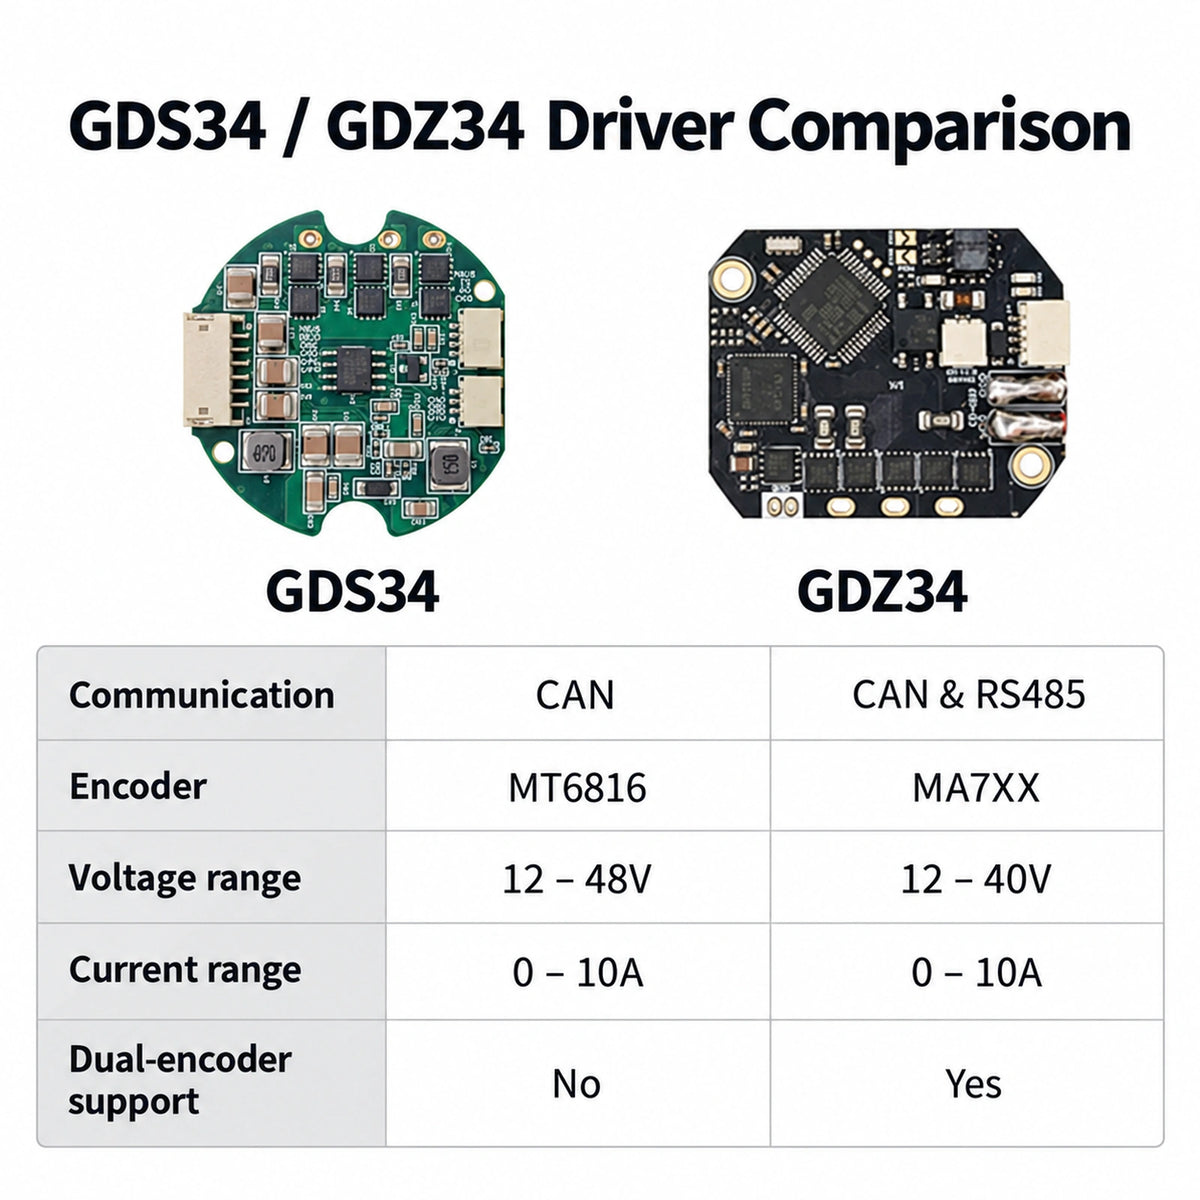
The GIM4310-36 supports an integrated motor driver with CAN communication and 14-bit encoder feedback. Two driver configurations are available: GDS34 with CAN communication and GDZ34 with CAN/RS485 communication.
With its compact size, high reduction ratio, steel planetary gears and high torque density, the GIM4310-36 is suitable for compact robotic joints where installation space and weight are critical.
Key Features
- Compact Ø55 mm robot joint actuator
- 24V nominal operating voltage
- 12–36V specified voltage range with SDC101 driver
- 55W rated power
- 7.38 N·m nominal torque
- Up to 20.16 N·m stall torque
- 36:1 planetary gear reduction
- Steel planetary gears
- CAN communication
- 14-bit encoder feedback with driver
- Optional GDS34 or GDZ34 driver configuration
- Up to 500N radial load
- IP54 motor protection rating
- Optional custom brake support
- Designed for quadruped robots and compact robotic joints
Specifications
| Specification | Value |
|---|---|
| Model | GIM4310-36 |
| Motor Type | Robot Joint Servo Actuator |
| Nominal Voltage | 24 V |
| Voltage Range | 12–36 V* |
| Rated Power | 55 W |
| Nominal Torque | 7.38 N·m |
| Stall Torque | 20.16 N·m |
| Nominal Output Speed | 41 RPM |
| Maximum Output Speed | 63 RPM |
| Nominal Current | 2.3 A |
| Stall Current | 6.8 A |
| Phase Resistance | 1.89 Ω |
| Phase Inductance | 0.75 mH |
| Speed Constant | 2.63 RPM/V |
| Torque Constant | 3.46 N·m/A |
| Number of Pole Pairs | 14 |
| Gear Ratio | 36:1 |
| Gear Type | Planetary |
| Gear Material | Steel |
| Gear Backlash | 15 arcmin |
| Weight Without Driver | 300 g |
| Weight With Driver | 310 g |
| Size Without Driver | Ø55 × 40 mm |
| Size With Driver | Ø55 × 47 mm |
| Maximum Axial Load | 125 N |
| Maximum Radial Load | 500 N |
| Noise | <60 dB |
| Communication | CAN* |
| Encoder Resolution on Driver | 14-bit |
| Second Encoder | No |
| Separate Encoder Support | No |
| Motor Protection Rating | IP54 |
| Working Temperature | -20°C to +80°C |
| Custom Brake Support | Yes |
* Driver voltage range and communication interface depend on the selected driver configuration.
Driver Options
| Driver | Communication | Encoder | Voltage Range | Current Range | Dual Encoder |
|---|---|---|---|---|---|
| GDS34 | CAN | MT6816 | 12–48 V | 0–10 A | No |
| GDZ34 | CAN / RS485 | MA7XX | 12–40 V | 0–10 A | Yes |
Important: The main GIM4310-36 specification sheet lists an SDC101 driver with a 12–36V operating range. Driver specifications vary by configuration; use the specifications corresponding to the selected driver.
这样写最稳妥,不把不同图片里的电压范围强行混成一个参数。
GDS34 Interface
| Wire / Interface | Function |
|---|---|
| CANH – White | CAN-H |
| CANL – Yellow | CAN-L |
| GND – Black | Negative Power Supply |
| GND – Black | Negative Power Supply |
| VBUS – Red | Positive Power Supply |
| VBUS – Red | Positive Power Supply |
Debug Interface
| Interface | Function |
|---|---|
| VBUS – Yellow | Output Power Positive |
| TX – White | TX |
| RX – Red | RX |
| GND – Black | Output Power Negative |
GDS34 Notes
- Do not hot-plug the driver board during operation.
- CP2102 module is required for host-computer debugging.
- Do not repeatedly connect the VBUS pin on the debugging interface.
Dimensions
| Dimension | Value |
|---|---|
| Motor Diameter | Ø55 mm |
| Length Without Driver | 40 mm |
| Length With Driver | 47 mm |
| Front Reference Diameter | Ø50 ±0.10 mm |
| Front Reference Diameter | Ø27 ±0.10 mm |
| Front Reference Diameter | Ø25 ±0.10 mm |
| Front Reference Diameter | Ø20.4 ±0.10 mm |
| Rear Reference Diameter | Ø51 mm |
| Rear Reference Diameter | Ø38 mm |
For installation, use the detailed mechanical drawing to confirm mounting-hole locations and tolerances.
Applications
- Quadruped robot joints
- Robot dog joints
- Humanoid robots
- Robotic arms
- Exoskeleton systems
- Compact robot actuators
- Research robots
- Mobile robot mechanisms
- Precision rotary joints
- Automation equipment
Package Includes
Package contents depend on the selected configuration.
| Configuration | Package Contents |
|---|---|
| GIM4310-36 Motor Only | 1 × GIM4310-36 Actuator |
| GIM4310-36 + GDS34 | 1 × GIM4310-36 Actuator with GDS34 Driver |
| GIM4310-36 + GDZ34 | 1 × GIM4310-36 Actuator with GDZ34 Driver |
FAQ
What is the gear ratio of the GIM4310-36?
The actuator uses a 36:1 planetary gearbox with steel gears.
What is the nominal output torque?
The specified nominal torque is 7.38 N·m.
What is the maximum stall torque?
The specified stall torque is 20.16 N·m.
What is the output speed?
The nominal output speed is 41 RPM, with a specified maximum speed of 63 RPM.
Does the actuator support CAN communication?
Yes. CAN communication is available with the driver-equipped configurations.
What is the difference between GDS34 and GDZ34?
GDS34 supports CAN communication and uses an MT6816 encoder. GDZ34 supports CAN/RS485 communication, uses an MA7XX encoder and supports dual encoders according to the supplied driver specifications.
Does the motor support a second encoder?
The main GIM4310-36 specification lists no second encoder. However, the supplied GDZ34 driver specification indicates dual-encoder support. This capability therefore depends on the selected driver configuration and system implementation.
Can a brake be added?
Yes. The supplied specification lists support for a custom brake.
Is the motor waterproof?
The motor protection grade is specified as IP54. It should not be described as waterproof.