Description
The GW12T-050 is a compact DC worm gear motor designed for space-limited robotic and electromechanical applications. Its steel-plate gearbox structure combines a small 11-size brushed DC motor with a right-angle output shaft, allowing the motor to fit into compact mechanisms where a conventional inline gear motor may be unsuitable.
Available in 6V and 12V configurations with six gear ratios, this motor provides rated output speeds from 6 to 300 RPM. The 3mm output shaft and compact gearbox make it suitable for miniature robots, self-balancing vehicles, inspection cars, camera mechanisms and small automatic equipment.
Select the operating voltage and gear ratio according to the required speed and load. Avoid prolonged stall operation and do not exceed the recommended gearbox load.
Key Features
- Compact right-angle DC gear motor
- Steel-plate gearbox construction
- Available in 6V and 12V versions
- Six selectable gear ratios from 1:42 to 1:1030
- Rated output speeds from 6 to 300 RPM
- 3mm diameter, 8mm long output shaft
- Lightweight design at approximately 23g
- Suitable for compact robotic and automation mechanisms
- Multiple mounting holes integrated into the gearbox plate
Specifications
General Specifications
| Parameter | Specification |
|---|---|
| Model | CHF-GW12T-050 |
| Motor Type | Brushed DC worm gear motor |
| Gearbox Structure | Steel-plate right-angle gearbox |
| Rated Voltage Options | 6V or 12V |
| Motor Power at 6V | 0.15W |
| Motor Power at 12V | 0.55W |
| Gear Ratio Options | 1:42, 1:118, 1:236, 1:302, 1:603, 1:1030 |
| Output Shaft Diameter | 3mm |
| Output Shaft Length | 8mm |
| Output Shaft Flat Width | 2.5mm |
| Motor Body Length | 26.9mm reference |
| Gearbox Length | 18mm |
| Approximate Overall Length | 44.9mm, excluding output shaft |
| Gearbox Width | 12mm |
| Gearbox Height | 10mm |
| Motor Height | 15.5mm |
| Approximate Weight | 23g |
| Encoder | Not included |
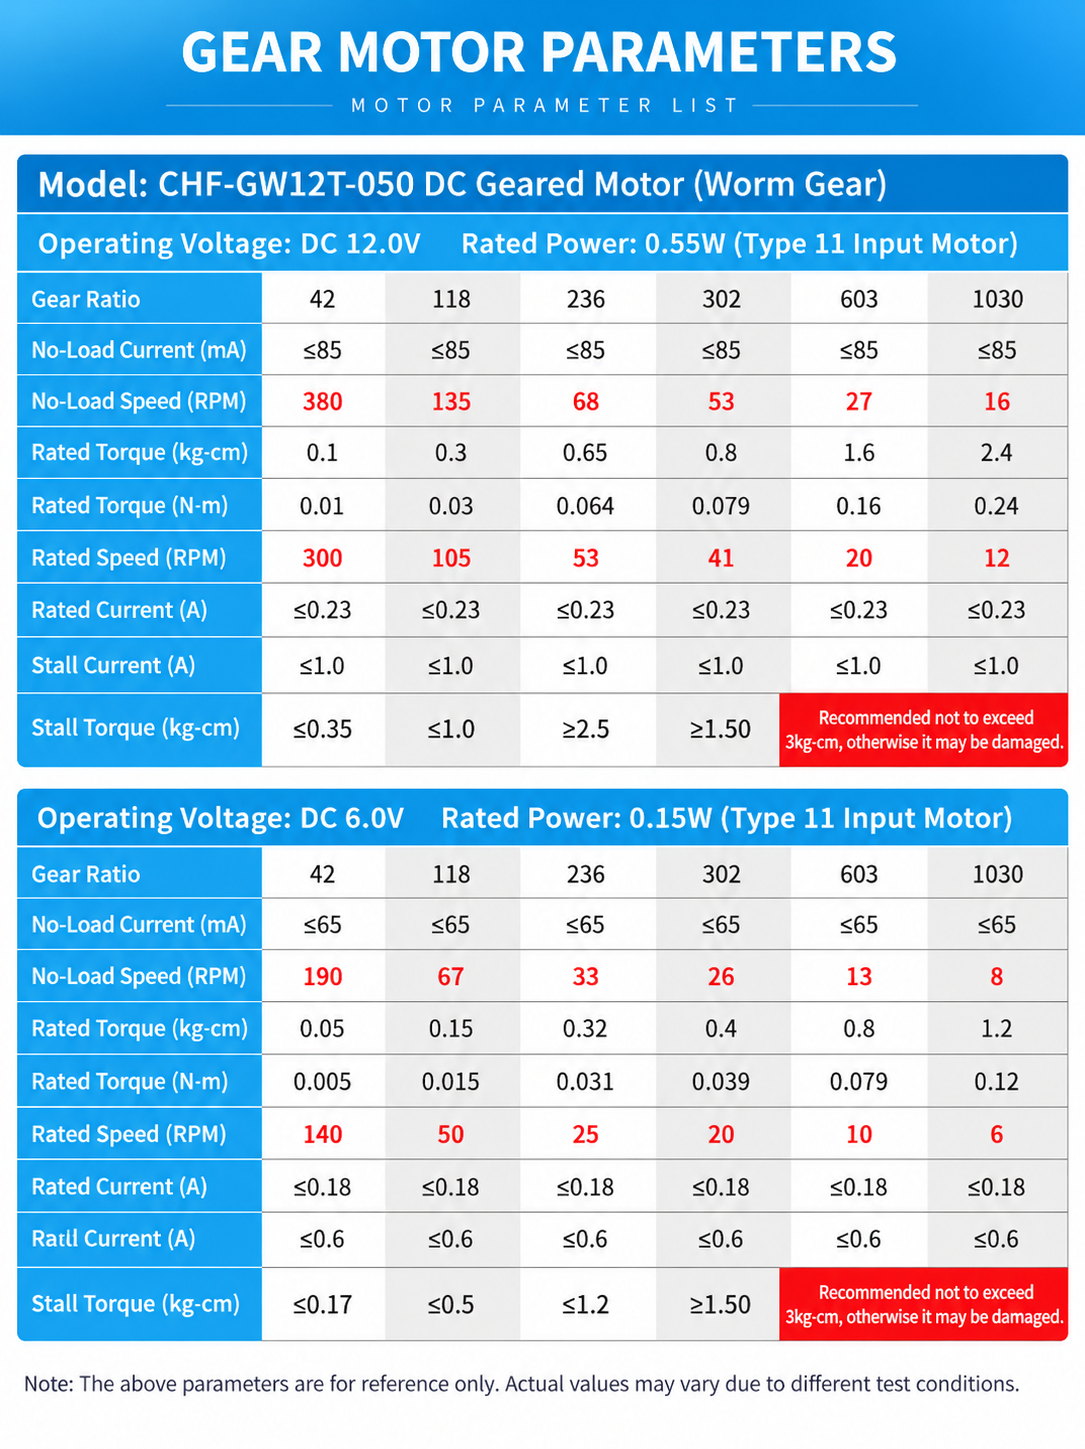
12V Performance
| Gear Ratio | No-Load Speed | Rated Speed | Rated Torque | No-Load Current | Rated Current |
|---|---|---|---|---|---|
| 1:42 | 380 RPM | 300 RPM | 0.10 kg·cm / 0.010 N·m | ≤85mA | ≤0.23A |
| 1:118 | 135 RPM | 105 RPM | 0.30 kg·cm / 0.030 N·m | ≤85mA | ≤0.23A |
| 1:236 | 68 RPM | 53 RPM | 0.65 kg·cm / 0.064 N·m | ≤85mA | ≤0.23A |
| 1:302 | 53 RPM | 41 RPM | 0.80 kg·cm / 0.079 N·m | ≤85mA | ≤0.23A |
| 1:603 | 27 RPM | 20 RPM | 1.60 kg·cm / 0.160 N·m | ≤85mA | ≤0.23A |
| 1:1030 | 16 RPM | 12 RPM | 2.40 kg·cm / 0.240 N·m | ≤85mA | ≤0.23A |
6V Performance
| Gear Ratio | No-Load Speed | Rated Speed | Rated Torque | No-Load Current | Rated Current |
|---|---|---|---|---|---|
| 1:42 | 190 RPM | 140 RPM | 0.05 kg·cm / 0.005 N·m | ≤65mA | ≤0.18A |
| 1:118 | 67 RPM | 50 RPM | 0.15 kg·cm / 0.015 N·m | ≤65mA | ≤0.18A |
| 1:236 | 33 RPM | 25 RPM | 0.32 kg·cm / 0.031 N·m | ≤65mA | ≤0.18A |
| 1:302 | 26 RPM | 20 RPM | 0.40 kg·cm / 0.039 N·m | ≤65mA | ≤0.18A |
| 1:603 | 13 RPM | 10 RPM | 0.80 kg·cm / 0.079 N·m | ≤65mA | ≤0.18A |
| 1:1030 | 8 RPM | 6 RPM | 1.20 kg·cm / 0.120 N·m | ≤65mA | ≤0.18A |
Stall and Load Information
| Voltage | Gear Ratio | Listed Stall Torque Information |
|---|---|---|
| 12V | 1:42 | ≤0.35 kg·cm |
| 12V | 1:118 | ≤1.0 kg·cm |
| 12V | 1:236 | ≥2.5 kg·cm |
| 6V | 1:42 | ≤0.17 kg·cm |
| 6V | 1:118 | ≤0.5 kg·cm |
| 6V | 1:236 | ≤1.2 kg·cm |
| 6V | 1:302 | ≤1.5 kg·cm |
| 6V/12V | High-ratio versions | Recommended operating load should not exceed 3 kg·cm |
Important: Stall operation is prohibited. Stall torque values are provided only as supplier reference data and should not be treated as continuous operating torque.
Package Includes
- 1 × GW12T-050 DC Worm Gear Motor in the selected voltage and gear ratio
Mounting hardware, motor driver, controller, wheel, coupling and encoder are not included unless separately specified.
Applications
- Miniature mobile robots
- Self-balancing two-wheel robots
- Smart inspection vehicles
- Small home-service robots
- Camera pan and tilt mechanisms
- Motorized paper-cutting mechanisms
- Compact rotating platforms
- Educational robotics projects
- Small automatic devices
- DIY electromechanical mechanisms
FAQ
What is the difference between the 6V and 12V versions?
The two versions share the same mechanical dimensions but use different motor windings. At the same gear ratio, the 12V version provides a higher rated speed and rated torque than the 6V version.
Which gear ratio should I choose for a small robot?
Choose 1:42 or 1:118 when higher movement speed is required. Ratios from 1:236 to 1:603 provide lower speed and increased torque. The 1:1030 version is intended for very slow output.
Does this motor include an encoder?
No. The supplied configuration is a brushed DC worm gear motor without an encoder.
Can the motor rotate in both directions?
A brushed DC motor normally reverses direction when the power-supply polarity is reversed. Use a compatible reversible DC motor driver when electronic direction control is required.
What motor driver should I use?
Use a brushed DC motor driver that supports the selected 6V or 12V supply and provides sufficient current capacity. The listed rated current is up to 0.18A at 6V and 0.23A at 12V, while startup current can be higher.
Can this motor operate continuously at stall?
No. Do not lock the output shaft or operate the motor continuously under stall conditions. Prolonged stalling can damage the motor or gearbox.
Is the output shaft compatible with a 3mm coupling?
The nominal shaft diameter is 3mm with a 2.5mm flat section. Confirm the coupling design and dimensional tolerance before installation.
Is this motor suitable for precision position control?
The motor does not include an encoder, so closed-loop positioning requires an external position or speed sensor and a compatible controller.