Description
HT-N3 Integrated Robotic Joint Actuator with MIT Driver
The HT-N3 Robotic Joint Actuator is a compact, high-torque integrated servo actuator designed for humanoid robots, exoskeletons, robotic arms, quadruped robots, and advanced motion control systems. Combining a brushless servo motor, 6:1 precision planetary gearbox, integrated position sensing, and an MIT-compatible open-source driver, it provides a complete actuator solution that simplifies mechanical integration and control system development.
Powered by 24V with an operating range of 12–24V, the actuator delivers 3 Nm rated torque, 9 Nm peak torque, and up to 400 RPM output speed after reduction. The integrated CAN communication interface enables reliable real-time control for distributed robotic architectures.
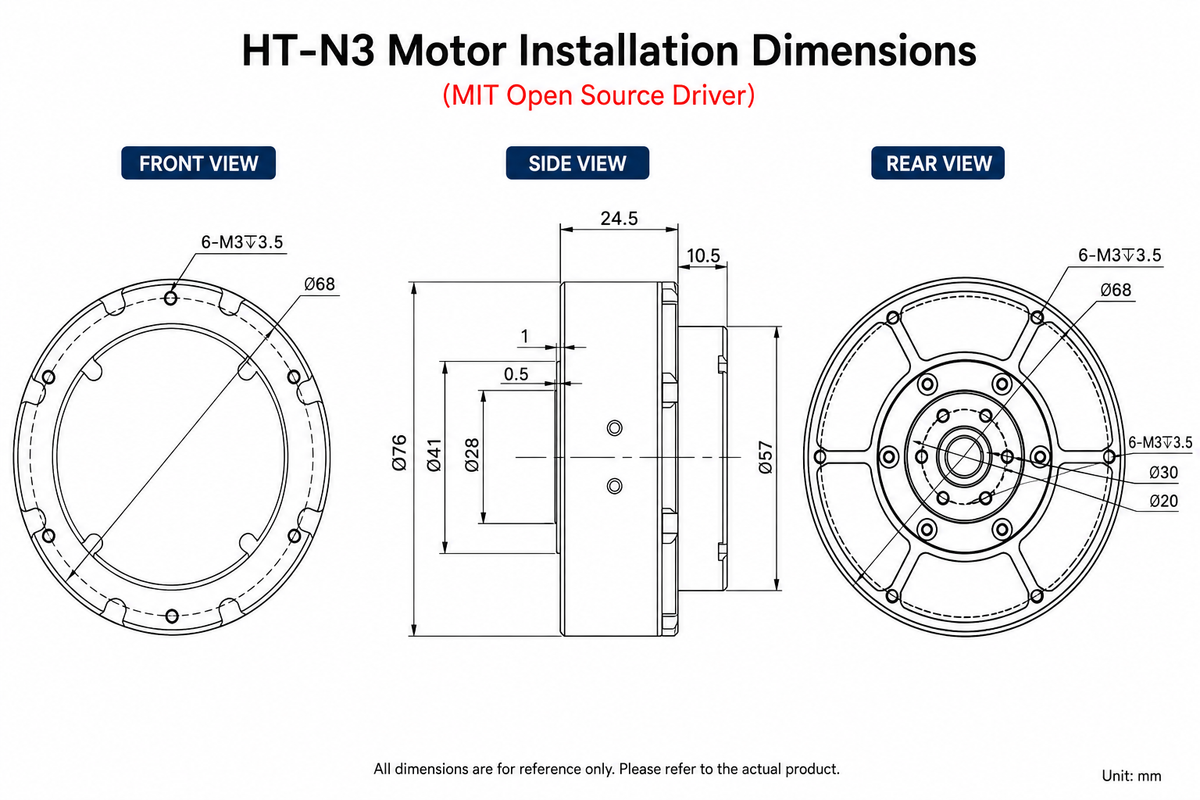
Its compact Ø76 mm housing, lightweight structure, low-backlash planetary gearbox, and integrated electronics make the HT-N3 an ideal solution for applications requiring high torque density, compact size, and smooth servo performance.
Whether developing robotic joints, wearable robotics, service robots, educational platforms, or research equipment, the HT-N3 provides a ready-to-deploy actuator for demanding motion control applications.
Key Features
- Integrated brushless servo actuator
- Built-in MIT compatible open-source driver
- Precision 6:1 planetary gearbox
- 24V rated voltage (12–24V operating range)
- 3 Nm rated torque
- 9 Nm peak torque
- Up to 400 RPM output speed
- CAN communication interface
- Integrated position sensing
- Compact Ø76 mm actuator housing
- Steel planetary gearbox
- Low backlash (15 arcmin)
- IP54 protection
- Lightweight integrated construction
- Designed for robotic joint applications
Specifications
| Parameter | Specification |
|---|---|
| Model | HT-N3 |
| Driver | MIT Open Source Driver |
| Rated Voltage | 24 V |
| Operating Voltage | 12–24 V |
| Rated Power | 96 W |
| Rated Torque | 3 Nm |
| Peak Torque | 9 Nm |
| Rated Output Speed | 300 RPM |
| Maximum Output Speed | 400 RPM |
| Rated Current | 4 A |
| Peak Current | 13 A |
| Phase Resistance | 0.55 Ω |
| Phase Inductance | 0.45 mH |
| Speed Constant | 16.67 rpm/V |
| Torque Constant | 0.68 Nm/A |
| Pole Pairs | 14 |
| Gear Ratio | 6:1 |
| Gearbox Type | Planetary |
| Gear Material | Steel |
| Gearbox Backlash | 15 arcmin |
| Communication | CAN |
| Secondary Encoder | No |
| Protection Rating | IP54 |
| Operating Temperature | -20°C to +80°C |
| Encoder Resolution (On Driver) | 12 Bit |
| Maximum Axial Load | 200 N |
| Maximum Radial Load | 800 N |
| Noise | <60 dB |
| Weight | 318 g |
| Dimensions | Ø76 × 35 mm |
Package Includes
- 1 × HT-N3 Robotic Joint Actuator
- Integrated MIT Driver
- Built-in 6:1 Planetary Gearbox
- Integrated Position Sensor
Applications
- Humanoid Robots
- Robotic Arms
- Robot Joint Modules
- Exoskeleton Systems
- Quadruped Robots
- Legged Robots
- Service Robots
- Industrial Automation
- Motion Control Equipment
- Educational Robotics
- Laboratory Research Platforms
- Precision Servo Systems
FAQ
What is the HT-N3 Robotic Joint Actuator?
The HT-N3 is an integrated servo actuator combining a brushless motor, planetary gearbox, position sensing, and an MIT-compatible driver into one compact module.
Does this version include the driver?
Yes. This version includes the integrated MIT open-source compatible driver.
Which communication protocol does it support?
The actuator communicates through the CAN interface.
What is the rated torque?
Rated torque is 3 Nm, with a peak torque of 9 Nm.
What gearbox is integrated?
A precision 6:1 planetary gearbox with steel gears and approximately 15 arcmin backlash.
Can it be used in humanoid robots?
Yes. The compact design and integrated electronics make it suitable for humanoid robots, robotic arms, exoskeletons, and legged robots.
What operating voltage is supported?
Rated voltage is 24V with an operating range of 12–24V.
Is the encoder integrated?
Yes. The actuator includes integrated position sensing. According to the provided specifications, no secondary encoder is included.