Description
The HAITAI HT10015-J9 is a high-torque integrated robot joint actuator designed for robotic arms, humanoid robots, wheel-legged robots, quadruped robots, exoskeletons, and other high-load robotic motion systems.
It combines a 264W brushless servo motor with a 9:1 planetary gearbox, delivering 21 N·m rated torque and up to 112 N·m peak torque while maintaining a compact Ø122 mm form factor.
The integrated-driver version features a 14-bit encoder and supports both CAN and RS485 communication, making the actuator suitable for advanced robot joint control and multi-axis robotic systems.
With a rated output speed of 101 RPM, low gearbox backlash, high radial load capacity, and IP54 protection, the HT10015-J9 is designed for robotic joints requiring a balance of high torque, compact construction, and precise electronic control.
Key Features
-
High-torque integrated robot joint actuator
-
264W brushless servo motor
-
9:1 planetary gearbox
-
21 N·m rated torque
-
Up to 112 N·m peak torque
-
101 RPM rated output speed
-
114 RPM maximum output speed
-
12–48V operating voltage range
-
48V rated voltage
-
CAN and RS485 communication
-
14-bit encoder resolution on driver version
-
Steel planetary gears
-
15 arcmin gearbox backlash
-
Up to 5000N radial load
-
IP54 protection
-
Optional custom brake support
-
Compact Ø122 mm joint actuator structure
Specifications
| Specification | Value |
|---|---|
| Model | HT10015-J9 |
| Driver Model | GDZ810 |
| Winding Type | Y |
| Rated Voltage | 48V |
| Voltage Range | 12–48V |
| Rated Power | 264W |
| Rated Torque | 21 N·m |
| Peak Torque | 112 N·m |
| Rated Speed After Reduction | 101 RPM |
| Maximum Speed After Reduction | 114 RPM |
| Rated Current | 5.5A |
| Peak Current | 39A |
| Phase-to-Phase Resistance | 0.76Ω |
| Phase-to-Phase Inductance | 0.42mH |
| Speed Constant | 2.38 rpm/V |
| Torque Constant | 1.5 N·m/A |
| Number of Pole Pairs | 21 |
| Gear Ratio | 9:1 |
| Gear Type | Planetary |
| Reducer Gear Material | Steel |
| Gearbox Backlash | 15 arcmin |
| Weight Without Driver | 1325g |
| Weight With Driver | 1372g |
| Size Without Driver | Ø122 × 45mm |
| Size With Driver | Ø122 × 57.5mm |
| Maximum Axial Load | 1250N |
| Maximum Radial Load | 5000N |
| Noise | <60dB |
| Communication | CAN & RS485 |
| Protection Grade | IP54 |
| Working Temperature | -20°C to +80°C |
| Driver Encoder Resolution | 14-bit |
| Second Encoder on Output Shaft | No |
| Separate Encoder Support | No |
| Custom Brake Support | Yes |
Communication Interface
The integrated GDZ810 driver provides:
| Interface | Function |
|---|---|
| CAN | Robot control communication |
| RS485 | Serial communication |
| GND | Ground |
| VCC | Power input |
| Power Connector | XT30 |
| Signal Connector | PHD2.0 |
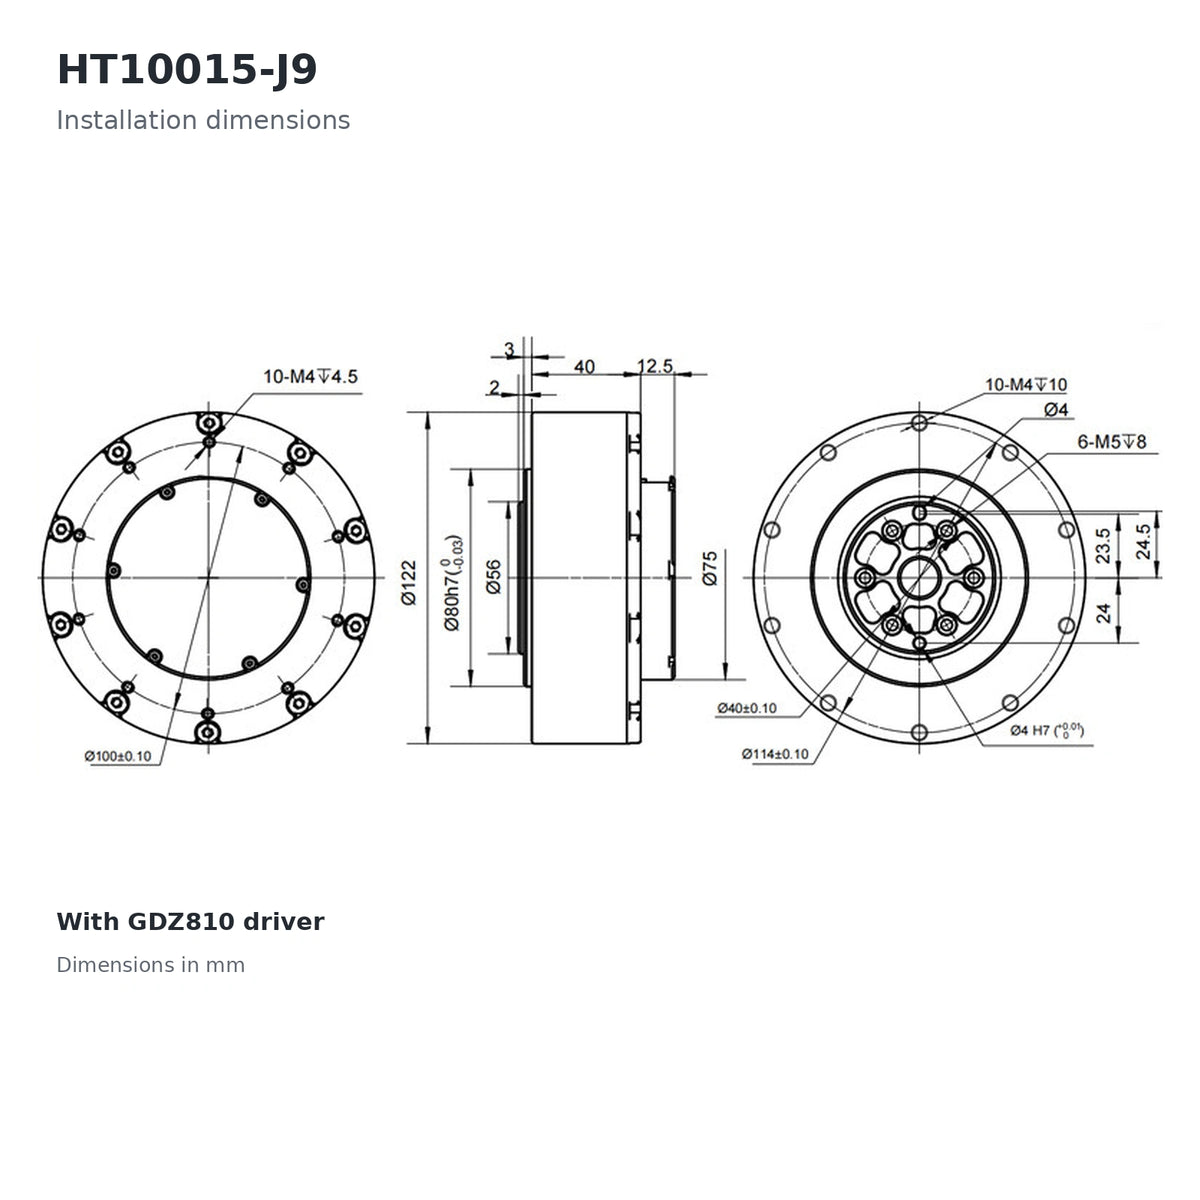
Mechanical Dimensions
With GDZ Driver
| Dimension | Value |
|---|---|
| Main Body Diameter | Ø122mm |
| Driver Version Overall Thickness | 57.5mm |
| Motor Body Section | 40mm |
| Driver Section | 12.5mm |
| Output Interface Diameter | Ø80 h7 |
| Rear Section Diameter | Ø75mm |
| Output Mounting Diameter | Ø100 ±0.10mm |
| Rear Mounting Diameter | Ø114 ±0.10mm |
Refer to the dimensional drawing for complete mounting-hole locations and tolerances before mechanical integration.
Applications
-
Humanoid robot joints
-
Dual-arm robots
-
Robotic arms
-
Wheel-legged robots
-
Quadruped robots
-
Exoskeleton systems
-
High-torque rotary joints
-
Research robotics platforms
-
Mobile manipulation robots
-
Industrial automation systems
Package Includes
Package contents depend on the selected configuration:
Motor + Gearbox
-
1 × HT10015-J9 Robot Joint Motor with Planetary Gearbox
Motor + Gearbox + Driver
-
1 × HT10015-J9 Robot Joint Motor with Planetary Gearbox
-
1 × Integrated GDZ810 Driver
Important Configuration Note
The motor-only version and driver-equipped version are not identical configurations.
The supplied product information states that the motor without driver does not include the second encoder by default. The driver-equipped model uses the integrated driver encoder with 14-bit resolution.
Customers requiring the complete electronic control configuration should select the Motor + Gearbox + Driver version.
FAQ
What is the rated and peak torque of the HT10015-J9?
The actuator provides 21 N·m rated torque and up to 112 N·m peak torque.
What type of gearbox does it use?
The HT10015-J9 uses a 9:1 planetary gearbox with steel gears.
Does it support CAN communication?
Yes. The GDZ810 driver-equipped version supports CAN and RS485 communication.
Does the actuator include a driver?
It depends on the selected configuration. Motor + Gearbox and Motor + Gearbox + Driver versions are available.
What is the encoder resolution?
The driver-equipped configuration specifies a 14-bit encoder.
Does the motor-only version include a second encoder?
No. According to the supplied product information, the motor without driver does not include a second encoder by default.
Can a separate encoder be connected?
No. The supplied specifications state that separate encoder support is not available.
Does it support a brake?
The specifications indicate that a custom brake configuration is supported. Brake requirements should be confirmed before ordering.
What communication interfaces are available?
The integrated driver supports CAN and RS485.
What is the operating voltage?
The rated voltage is 48V, with a specified operating voltage range of 12–48V.