Description
The HAITAI HT8115-J36-2E is a high-torque robot joint actuator designed for robotic arms, humanoid robots, quadruped robots, wheel-legged robots, exoskeletons, and other high-load robotic joint applications.
It combines a brushless servo motor with a 36:1 steel planetary gearbox in a compact Ø96 mm joint module. Multiple configurations are available, including 24V and 48V windings, Single Encoder or PRO Dual Encoder feedback, and versions with or without the GDZ810 servo driver.
The 24V version uses Delta (△) winding and provides 58 N·m rated torque with up to 190.2 N·m peak torque. The 48V version uses Y winding and provides 46 N·m rated torque with up to 214.3 N·m peak torque.
When configured with the GDZ810 driver, the actuator supports CAN and RS485 communication with a 14-bit driver-side encoder. The PRO Dual Encoder configuration adds a second encoder on the output shaft for enhanced joint position feedback.
With high torque, low output speed, compact dimensions, and flexible control configurations, the HT8115-J36-2E is suitable for demanding robotic joints requiring high load capacity and precise motion control.
Key Features
-
High-torque robot joint actuator
-
36:1 planetary reduction gearbox
-
24V and 48V versions available
-
24V Delta (△) winding
-
48V Y winding
-
Up to 58 N·m rated torque
-
Up to 214.3 N·m peak torque
-
Single Encoder and PRO Dual Encoder options
-
Optional GDZ810 servo driver
-
CAN and RS485 communication with GDZ810 driver
-
14-bit driver-side encoder
-
PRO version supports second output-shaft encoder
-
Steel planetary gears
-
15 arcmin specified gearbox backlash
-
Compact Ø96 mm housing
-
IP54 protection grade
-
Specified noise below 60dB
-
Custom brake support
-
Suitable for high-load robotic joints
Specifications
| Specification | 24V Version | 48V Version |
|---|---|---|
| Model | HT8115-J36-2E | HT8115-J36-2E |
| Compatible Driver | GDZ810 | GDZ810 |
| Winding Type | Delta (△) | Y |
| Rated Voltage | 24V | 48V |
| Voltage Range | 12–48V | 12–48V |
| Rated Power | 240W | 288W |
| Rated Torque | 58 N·m | 46 N·m |
| Peak Torque | 190.2 N·m | 214.3 N·m |
| Rated Speed After Reduction | 27 RPM | 32 RPM |
| Maximum Speed After Reduction | 35 RPM | 39 RPM |
| Rated Current | 10A | 6A |
| Peak Current | 48.91A | 39.5A |
| Phase-to-Phase Resistance | 0.324Ω | 1.06Ω |
| Phase-to-Phase Inductance | 157.07µH | 474.9µH |
| Speed Constant | 1.45 rpm/V | 0.81 rpm/V |
| Torque Constant | 5.4 N·m/A | 8 N·m/A |
| Pole Pairs | 21 | 21 |
| Gear Ratio | 36:1 | 36:1 |
| Gear Type | Planetary | Planetary |
| Gear Material | Steel | Steel |
| Gearbox Backlash | 15 arcmin | 15 arcmin |
| Weight Without Driver | 920g | 920g |
| Weight With Driver | 960g | 960g |
| Size Without Driver | Ø96 × 51.5mm | Ø96 × 51.5mm |
| Size With Driver | Ø96 × 64mm | Ø96 × 64mm |
| Maximum Axial Load | 250N | 250N |
| Maximum Radial Load | 1000N | 1000N |
| Noise | <60dB | <60dB |
| Communication with GDZ810 | CAN & RS485 | CAN & RS485 |
| Driver Encoder Resolution | 14-bit | 14-bit |
| Second Output Encoder | PRO Version | PRO Version |
| Protection Grade | IP54 | IP54 |
| Working Temperature | -20°C to +80°C | -20°C to +80°C |
| Custom Brake Support | Yes | Yes |
Encoder Options
Single Encoder
Standard encoder configuration for general robotic joint, robotic arm, automation, and motion-control applications.
PRO Dual Encoder
The PRO Dual Encoder version adds a second encoder on the output shaft for additional output-side position feedback.
Recommended for precision robotic joints, humanoid robots, quadruped robots, wheel-legged robots, and applications requiring enhanced joint position feedback.
Driver Options
Without Driver
Motor and planetary gearbox configuration without the GDZ810 driver.
Recommended for customers using their own compatible motor-control system.
With GDZ810 Driver
Includes the GDZ810 servo driver.
The driver supports:
-
CAN communication
-
RS485 communication
-
14-bit driver-side encoder feedback
-
Closed-loop robotic joint control
24V vs. 48V
| Parameter | 24V Version | 48V Version |
|---|---|---|
| Winding | Delta (△) | Y |
| Rated Power | 240W | 288W |
| Rated Torque | 58 N·m | 46 N·m |
| Peak Torque | 190.2 N·m | 214.3 N·m |
| Rated Speed | 27 RPM | 32 RPM |
| Maximum Speed | 35 RPM | 39 RPM |
| Rated Current | 10A | 6A |
| Peak Current | 48.91A | 39.5A |
The 24V version provides higher rated torque, while the 48V version provides higher peak torque and higher output speed.
Mechanical Specifications
| Specification | Value |
|---|---|
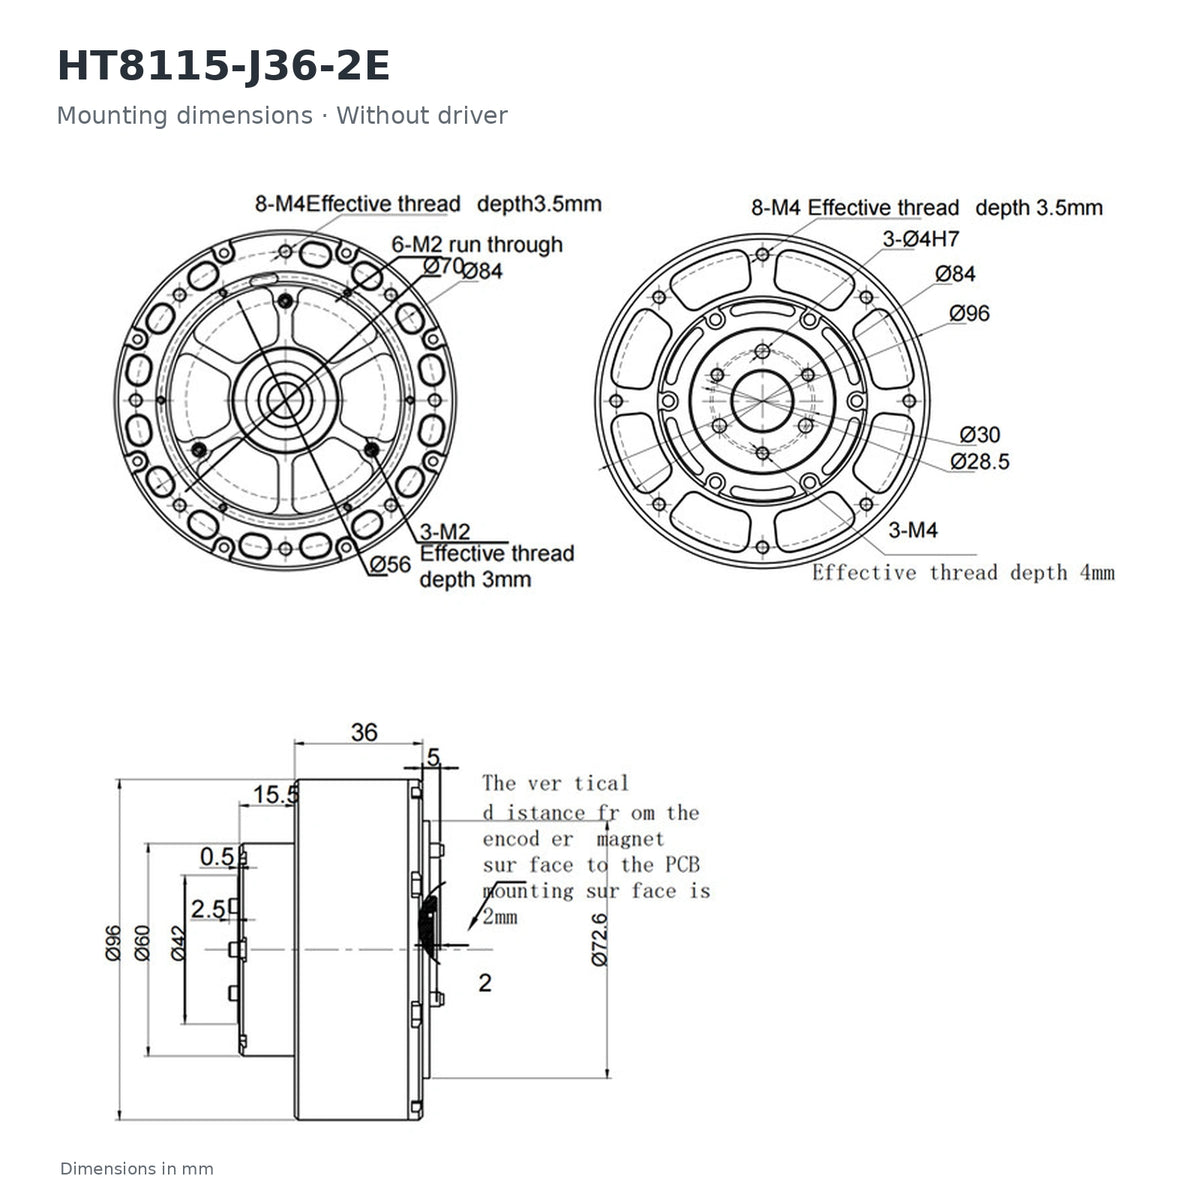
| Outer Diameter | Ø96mm |
| Gear Ratio | 36:1 |
| Gear Type | Planetary |
| Gear Material | Steel |
| Backlash | 15 arcmin |
| Weight Without Driver | 920g |
| Weight With Driver | 960g |
| Size Without Driver | Ø96 × 51.5mm |
| Size With Driver | Ø96 × 64mm |
| Maximum Axial Load | 250N |
| Maximum Radial Load | 1000N |
| Protection Grade | IP54 |
| Working Temperature | -20°C to +80°C |
Please refer to the dimensional drawings for complete mounting-hole locations, tolerances, output interface dimensions, and mechanical integration details.
Applications
-
Humanoid robots
-
Robotic arms
-
Quadruped robots
-
Robot dogs
-
Wheel-legged robots
-
Exoskeleton systems
-
High-torque robot joints
-
Mobile manipulation robots
-
Research robotics
-
Industrial automation
-
Precision rotary joints
What’s Included
Package contents depend on the selected configuration:
Without Driver
-
1 × HT8115-J36-2E Robot Joint Actuator
With GDZ810 Driver
-
1 × HT8115-J36-2E Robot Joint Actuator
-
1 × GDZ810 Driver
Encoder configuration depends on the selected Single Encoder or PRO Dual Encoder option.
FAQ
What is the gear ratio?
The HT8115-J36-2E uses a 36:1 planetary reduction gearbox.
What is the difference between the 24V and 48V versions?
The 24V model uses Delta (△) winding and provides 58 N·m rated torque. The 48V model uses Y winding and provides 46 N·m rated torque with higher peak torque and output speed.
What is the difference between Single Encoder and PRO Dual Encoder?
The PRO Dual Encoder version adds a second encoder on the output shaft for additional output-side position feedback.
Does the actuator include the GDZ810 driver?
The driver is optional. Select With GDZ810 Driver if an integrated driver is required.
Does it support CAN and RS485?
The GDZ810 driver configuration supports CAN and RS485 communication.
What is the driver encoder resolution?
The supplied GDZ810 specifications indicate a 14-bit encoder resolution.
What is the maximum torque?
The specified peak torque is 190.2 N·m for the 24V version and 214.3 N·m for the 48V version.
Which version has higher rated torque?
The 24V version has a specified rated torque of 58 N·m, compared with 46 N·m for the 48V version.
Which version has higher speed?
The 48V version has a rated output speed of 32 RPM and a maximum output speed of 39 RPM.
Does it support a custom brake?
Yes. The supplied specifications indicate support for a custom brake. Brake requirements should be confirmed before ordering.