Description
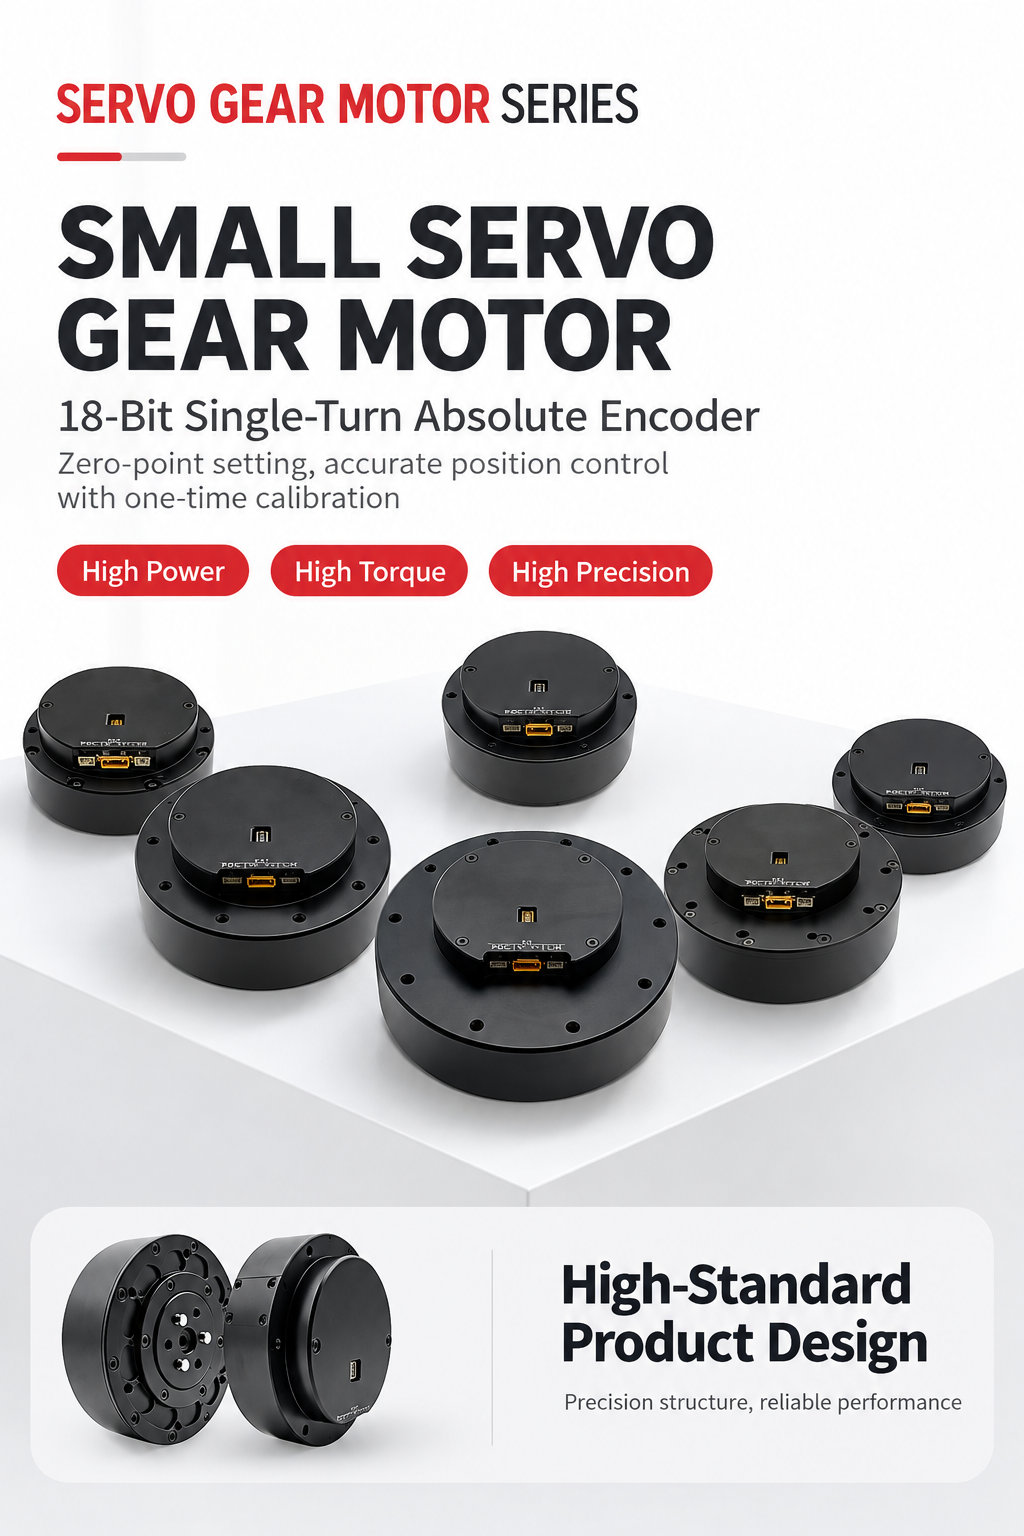
The TS9035-36 Integrated Robot Joint Servo Motor is a high-torque servo actuator designed for heavy-duty robotic joints, humanoid robots, robotic arms, quadruped robots, exoskeletons, and industrial automation systems.
The actuator combines a brushless servo motor, precision reduction gearbox, FOC servo driver, and encoder feedback system into a compact integrated joint module. This integrated architecture reduces external components and simplifies mechanical installation, wiring, and multi-axis robot development.
With 35 N·m rated output torque, the TS9035-36 is designed for robotic joints requiring substantially higher torque than compact 6–25 N·m actuators, making it suitable for larger robot arms and high-load humanoid or quadruped joints.
Multiple communication options are available, including CAN and RS485-based control configurations.
Key Features
- 35 N·m Rated Output Torque
- High-Torque Integrated Robot Joint Actuator
- Brushless Servo Motor
- Precision Reduction Gearbox
- Integrated FOC Servo Driver
- Encoder Feedback
- Position, Speed & Torque Control
- CAN / RS485 Communication Options
- Compact Integrated Joint Architecture
- High Torque Density
- Simplified Multi-Axis Integration
- Designed for Heavy-Load Robot Joints
Specifications
| Parameter | Specification |
|---|---|
| Model | TS9035-36 |
| Product Type | Integrated Robot Joint Servo Motor |
| Rated Torque | 35 N·m |
| Motor Type | Brushless Servo Motor |
| Motor Control | FOC |
| Gearbox | Integrated Reduction Gearbox |
| Encoder | Integrated |
| Control Modes | Position / Speed / Torque |
| Communication | CAN / RS485 Options |
| Brake | No brake version indicated |
| Application | Robot Joint / Robotic Arm / Humanoid Robot |
Communication Interface
| Interface | Function |
|---|---|
| A/H | RS485-A / CAN-H |
| B/L | RS485-B / CAN-L |
| V− | Power Supply Negative |
| V+ | Power Supply Positive |
| T | UART Transmitter |
| R | UART Receiver |
| G | Signal Ground |
Applications
- Humanoid Robot Joints
- Humanoid Robot Hip Joints
- Humanoid Robot Leg Joints
- High-Torque Robotic Arms
- Quadruped Robots
- Robot Dogs
- Exoskeleton Systems
- Collaborative Robots
- Industrial Robot Joints
- Research Robotics
- Multi-Axis Automation Systems
What’s Included
- 1 × TS9035-36 Integrated Robot Joint Servo Motor
- Integrated Reduction Gearbox
- Integrated FOC Driver
- Integrated Encoder
Communication adapters, USB-CAN modules, cables, and other accessories are not included unless specifically selected or stated.
FAQ
What is the rated torque of the TS9035-36?
The supplier lists the TS9035-36 with a 35 N·m rated torque.
Does it have an integrated driver?
Yes. This series uses an integrated servo architecture with an FOC motor driver.
Does it have encoder feedback?
Yes. The actuator integrates encoder feedback for closed-loop servo control.
Is a brake version available?
The supplier information you provided does not currently show a TS9035-36B version, so this Listing does not advertise an integrated brake.
What applications is the 35 N·m version suitable for?
It is intended for higher-load robotic joints, including robotic arms, humanoid robot joints, quadruped robots, exoskeleton systems, and industrial robotic mechanisms.